3 Degrees of Freedom Robotic Arm
- Where
- Personal project
- When
- January 2026
Objective
Design and build a 3-axis robotic arm that locates an object with a camera and picks it up autonomously, then extends the same kinematics to throw lightweight objects with controlled release timing. Concept through to an integrated mechanical and electrical system, 3D-printed and running on a Raspberry Pi.
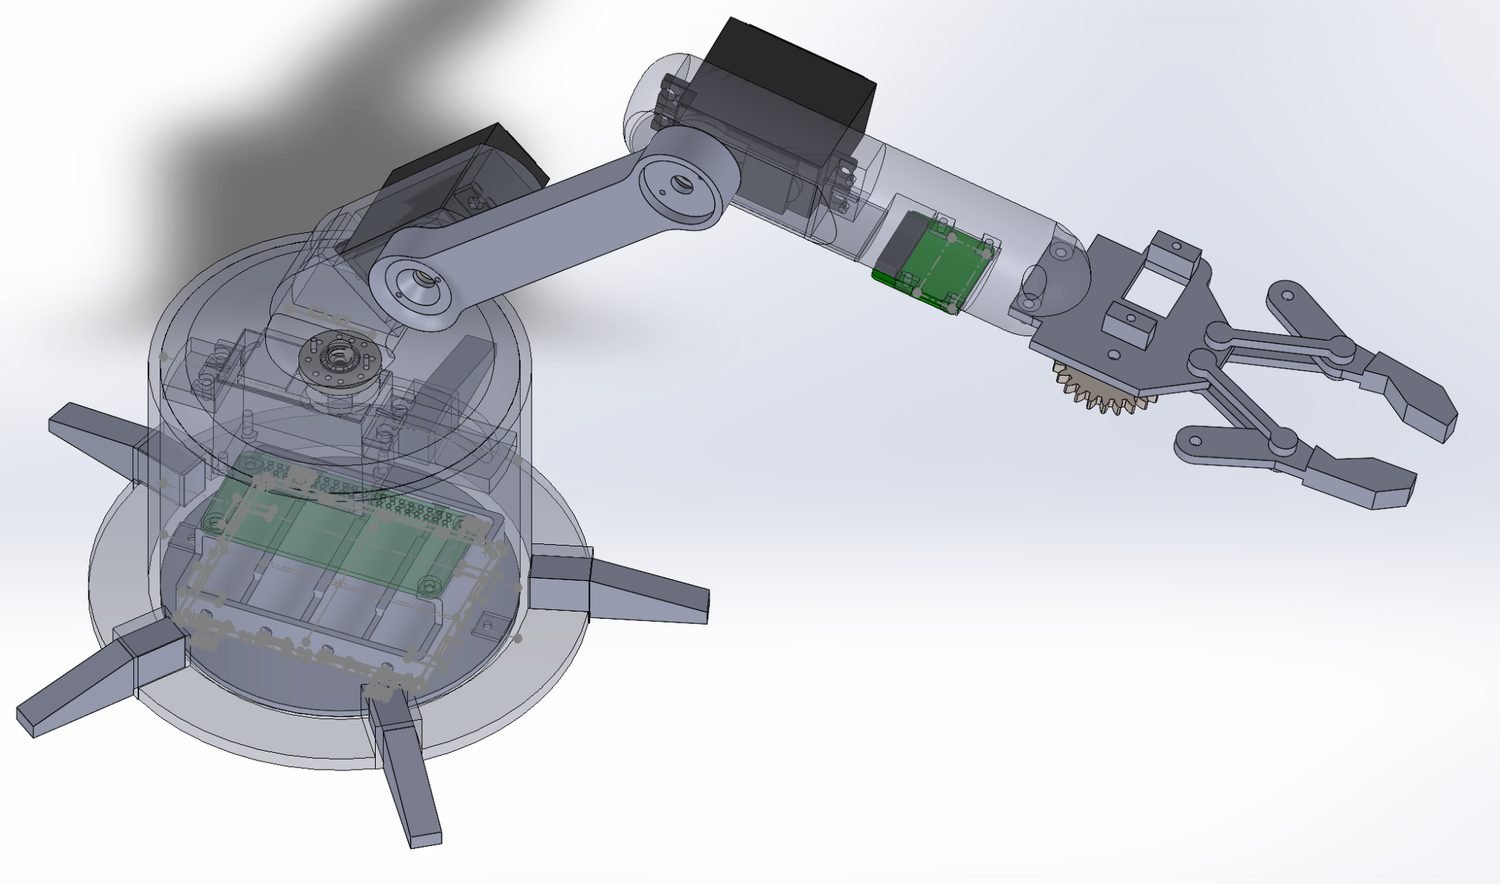
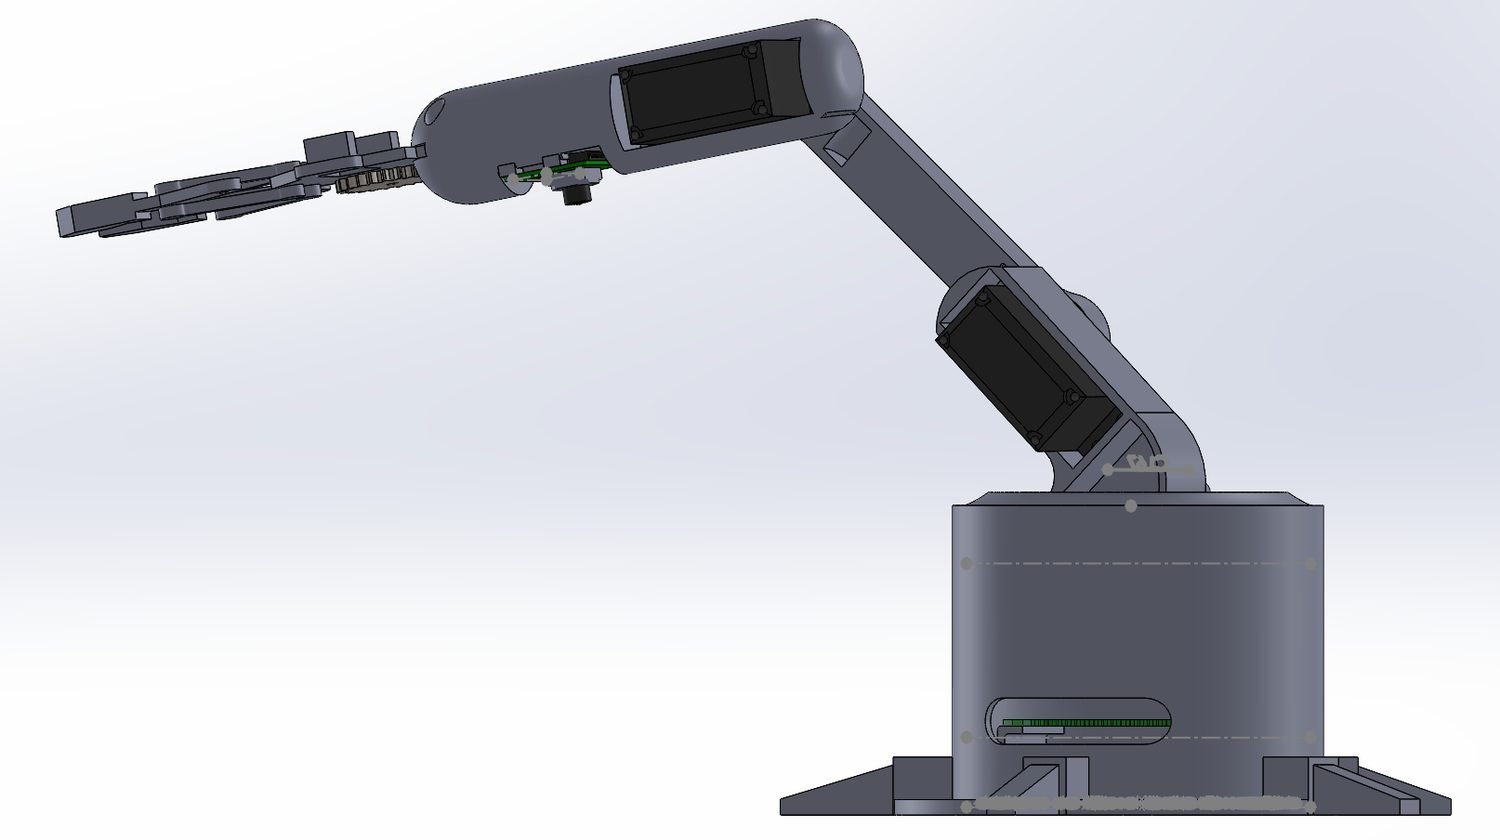
Outcomes and contributions
- Designed the full SolidWorks assembly and 3D printed the arm: base, three joints and gripper, with Raspberry Pi, battery and wiring integrated into the structure.
- Programmed forward kinematics and an iterative inverse kinematics solver in C++, turning camera-derived coordinates into real-time joint angles for autonomous grasping.
- Extended the kinematics into motion planning controlling release timing and trajectory for throwing.
Design decisions
- Utilized iterative inverse kinematics, converging numerically from the current joint pose.
- Toleranced for the process, accounting for print shrink and fit, fastener and joint clearances, so joints run smoothly and the arm reassembles repeatably.
- Wiring designed in, with channels, pass-throughs and strain relief keeping cables clear through the full range of motion.
- Housings sized around the electronics, with the Pi, battery and routing inside the base and arm rather than hanging off them.
Technical details and skills
- SolidWorks assembly, design for additive manufacturing, tolerance and fit analysis, design for assembly and serviceability.
- Forward and iterative inverse kinematics, motion planning and release timing in C++ on Raspberry Pi with live camera input.
- Mechanical and electrical integration: servo actuation, controller and power packaging, cable management.