Autocleat, self-deploying ice cleats
- Where
- EngHacks, 3rd place
- When
- March 2026
Objective
Design a shoe attachment that deploys ice spikes automatically when winter surfaces become unsafe. Conventional cleats work outdoors but have to be fitted and removed by hand, and damage floors indoors, so people either skip them or stop to switch modes at every transition. The goal was hands-free traction that adapts without the user bending down or pressing anything.
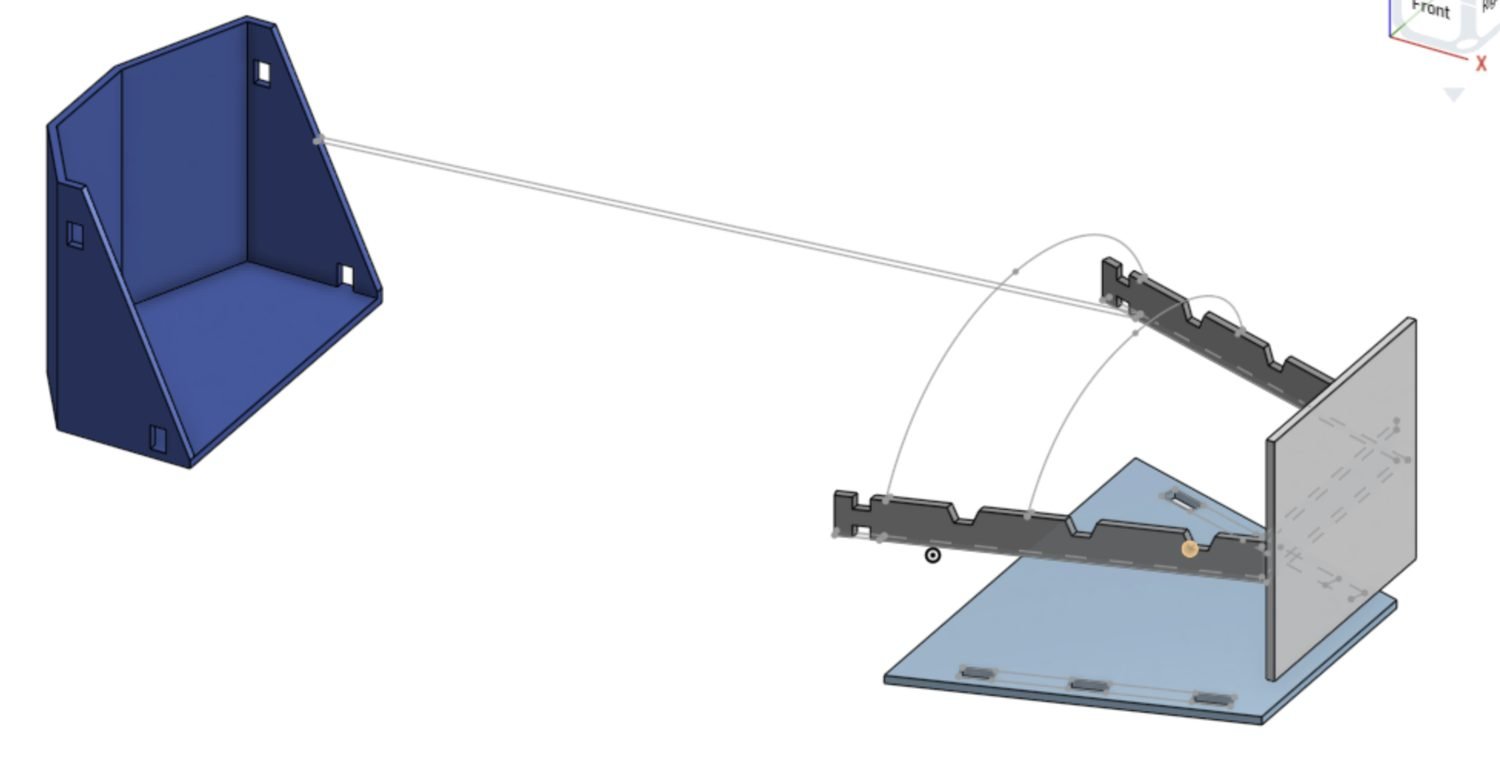
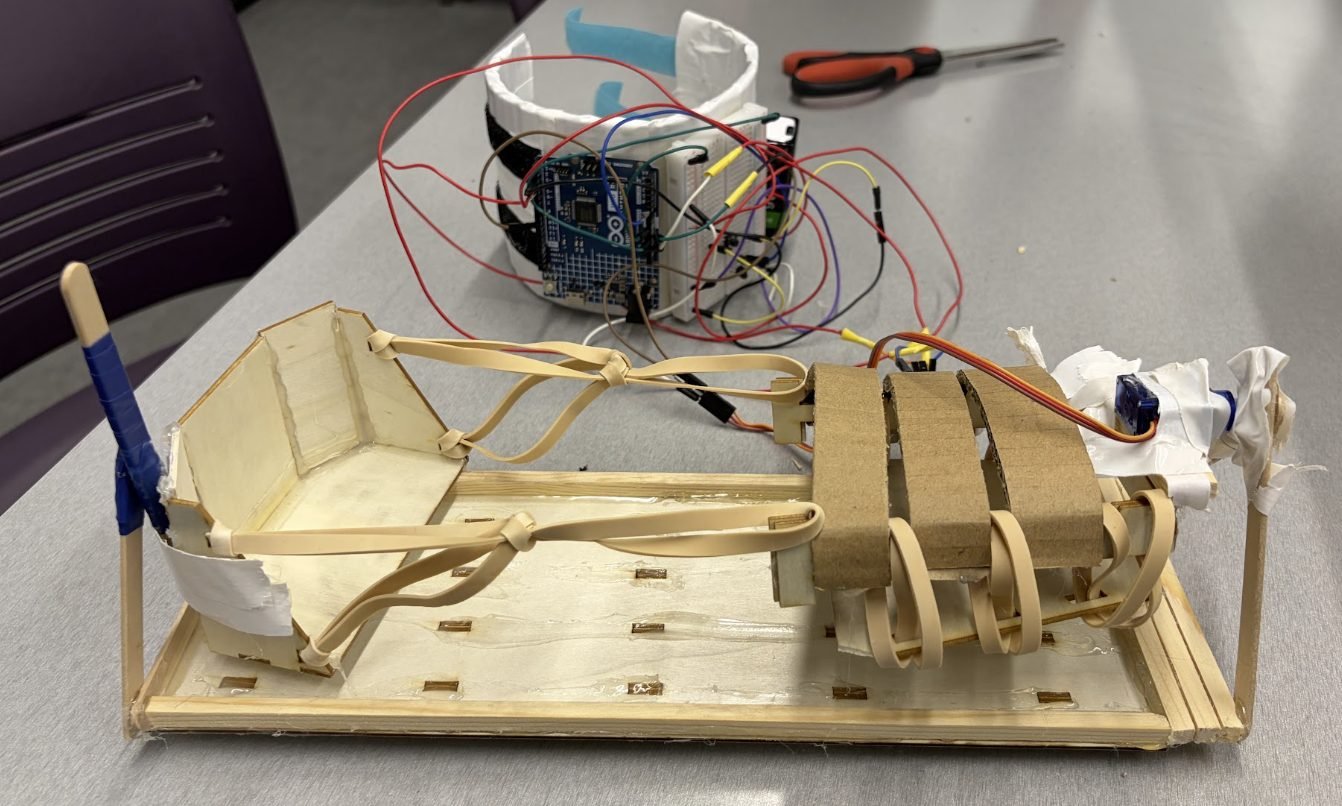
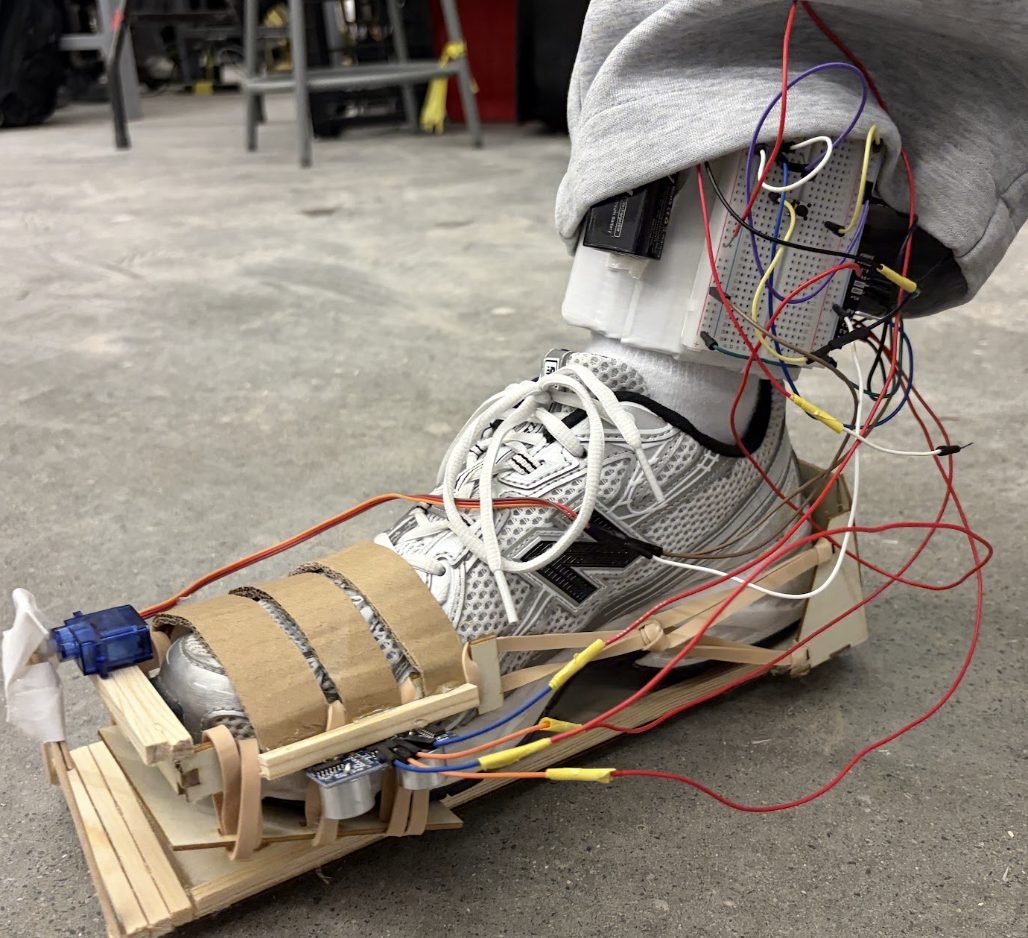
Demonstration video
Outcomes and contributions
- Co-designed and CAD-modelled a size-adjustable, servo-actuated attachment with retractable TPU spikes, built as a working prototype that deployed and retracted reliably in testing.
- Built the sensing and control on Arduino, pairing a temperature sensor to detect icy conditions with an ultrasonic sensor to detect foot lift.
- 3rd place at EngHacks, University of Waterloo.
Design decisions
- Deploy only during swing phase. The ultrasonic sensor confirms the foot is off the ground before the servo drives the spikes, so the mechanism never actuates under body weight. That keeps servo torque requirements low and protects the linkage.
- Two conditions, not one. Temperature alone would deploy on a cold indoor floor. Requiring both an icy-surface reading and a lifted foot means the spikes stay retracted wherever they would do harm.
- Elastomeric band for fit, so one unit adapts across shoe sizes without adjustment hardware.
Technical details and skills
- Onshape CAD assembly, with AutoCAD used to model wood pieces for laser cutting.
- Arduino sensing and control: temperature and ultrasonic input, servo actuation, state logic gating deployment on both conditions.
- Rapid prototyping under hackathon time constraint, mechanism and linkage design.