VEX Autonomous Maze Navigator
- Where
- Team project
- When
- November 2025
Run video
Video goes here
Upload the clip as assets/video/vex.mp4 or assets/video/vex.mov and it appears automatically.
- Collaborated in a team to design, build, and program a fully autonomous VEX IQ robot capable of maze navigation and object retrieval.
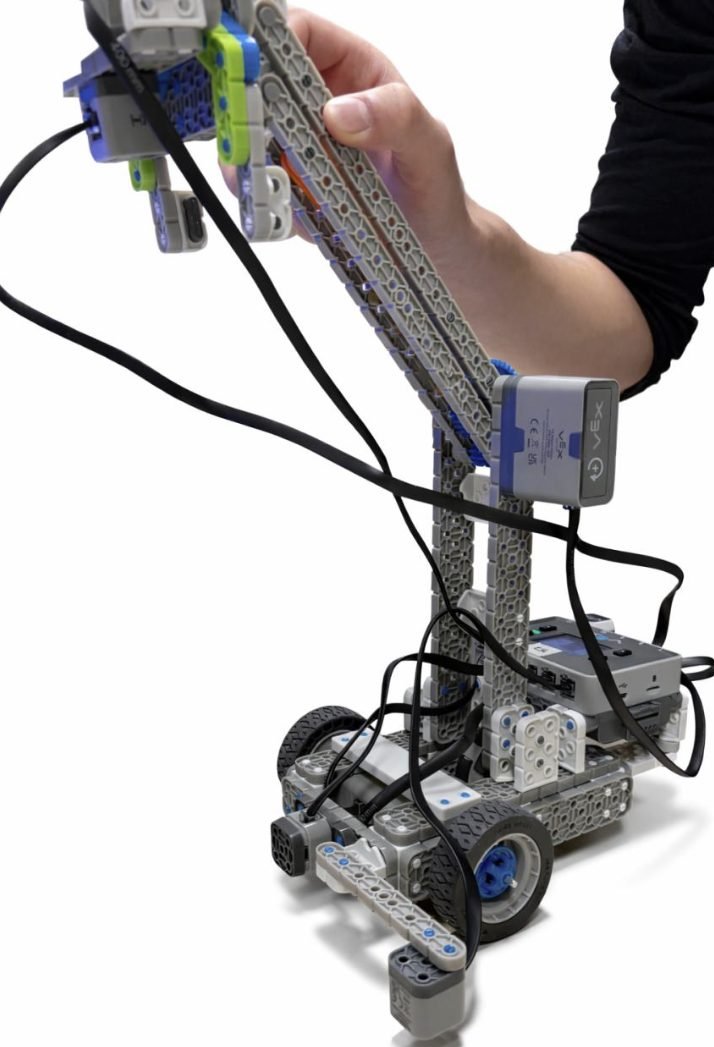
- Designed a 3-wheel drive chassis with a motor-driven arm and claw system to reliably retrieve objects placed at varying heights.
- Developed the full autonomy stack in C++ using the VEX IQ API, structuring the code with vectors, custom functions, and a directional state machine.
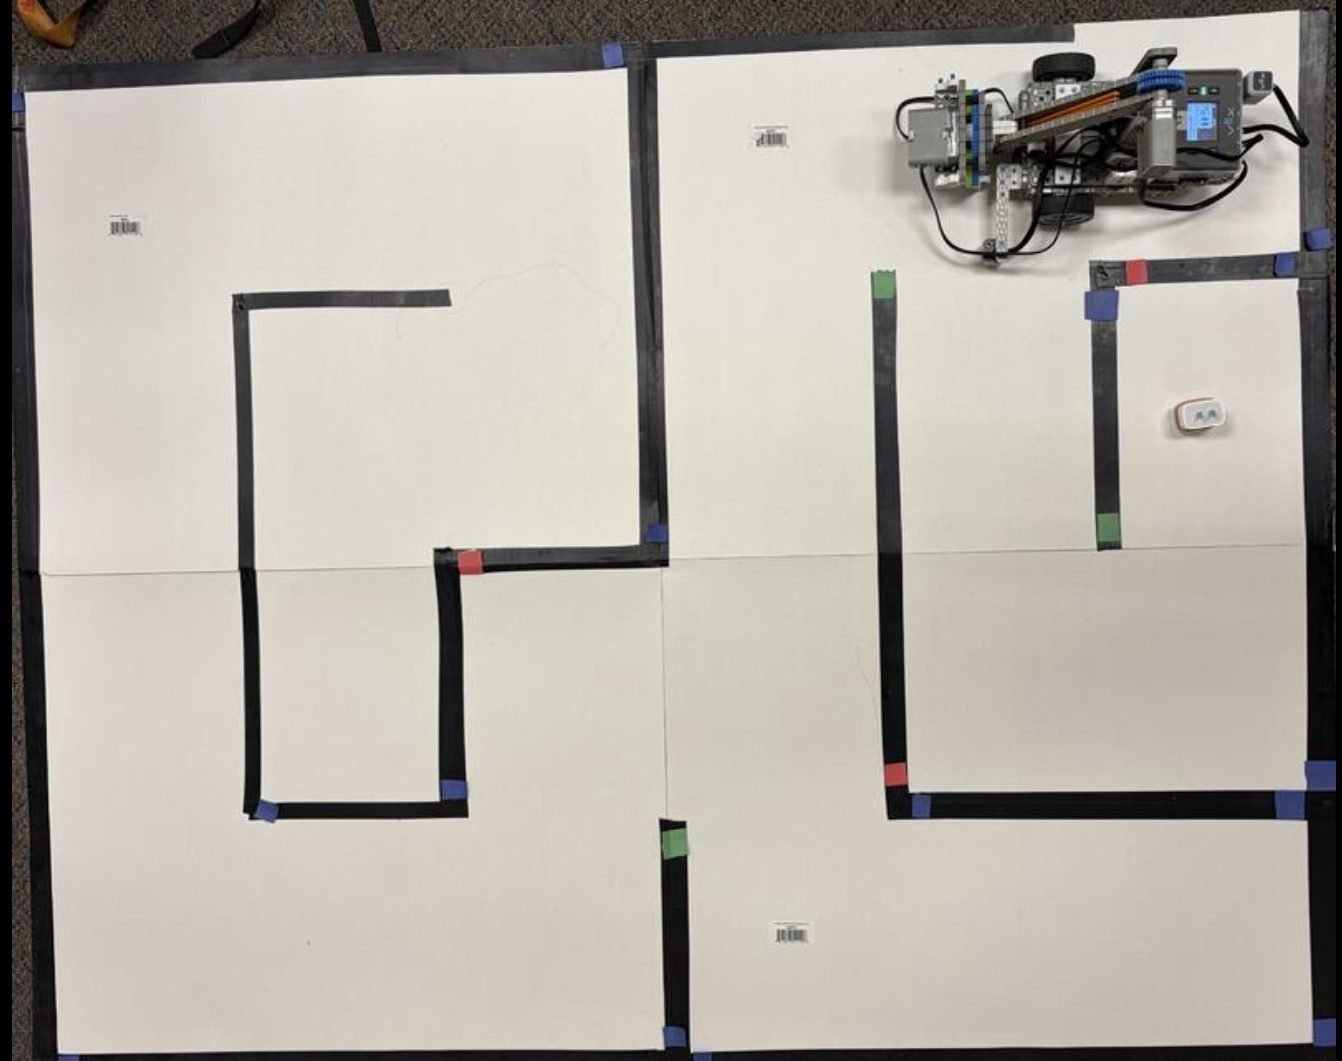
- Implemented autonomous maze exploration using line tracking, colour-coded intersections, and dead-end detection in an unknown grid-based environment.
- Integrated multi-sensor fusion using an inertial sensor, optical colour sensor, distance sensor, bumper sensor, touch LED, and motor encoders for robust environmental awareness.
- Logged navigation decisions (left, right, straight, U-turn) into an action vector, enabling path memory and post-processing.
- Designed a shortest-path return algorithm that compresses the explored route by eliminating loops and reversing/inverting turns after object retrieval.
- Implemented dynamic heading correction using inertial feedback and proportional speed control to maintain accurate alignment and reduce drift.
- Developed a sensor-triggered pickup sequence coordinating arm and claw motion once the object was detected.
- Tuned motion parameters for precise rotations, grid alignment, and line reacquisition, ensuring repeatable performance across multiple runs.