
Mechatronics engineer building mechanisms, fixtures and test hardware
Second-year Mechatronics Engineering student at the University of Waterloo. Most recently a mechanical engineering and testing intern at Forcen in Toronto, designing production tooling and safety enclosures and calibrating force sensors headed to robots in humanoid, surgical, and logistics applications.
Mechanical designer on the UW Rocketry controls subteam, where I work on canard actuation systems directly implemented into launched record-breaking rockets.
Away from engineering I play basketball, I love the outdoors, I'm an avid music geek, and I somehow lose every single one of my fantasy football leagues.
Click a project to read how it was designed and what came out of it.
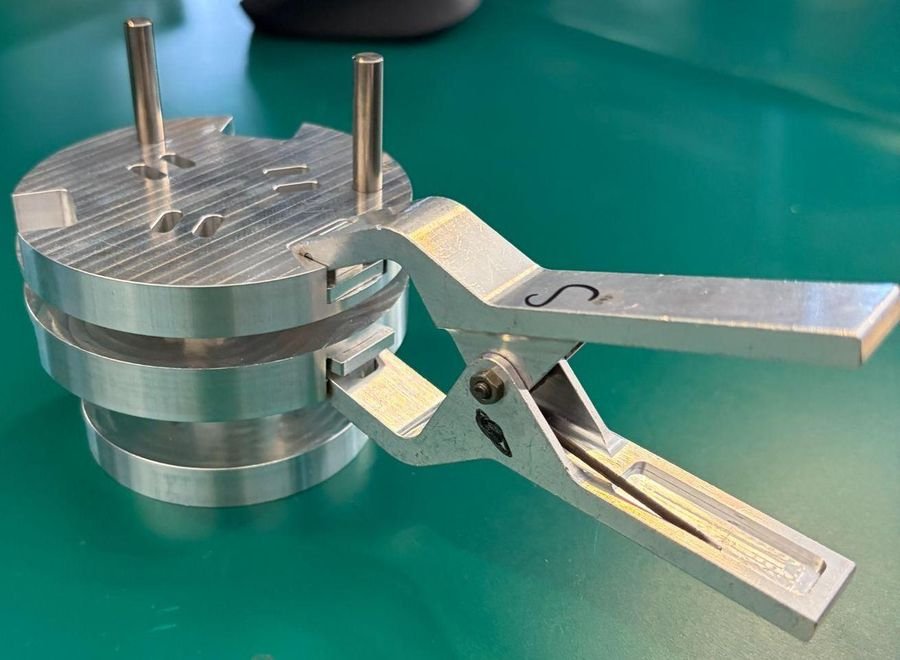
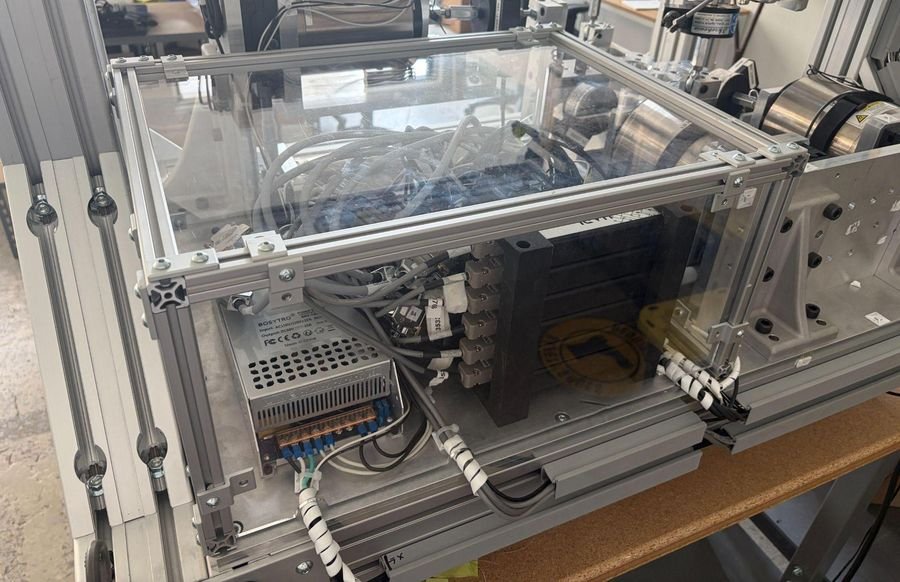
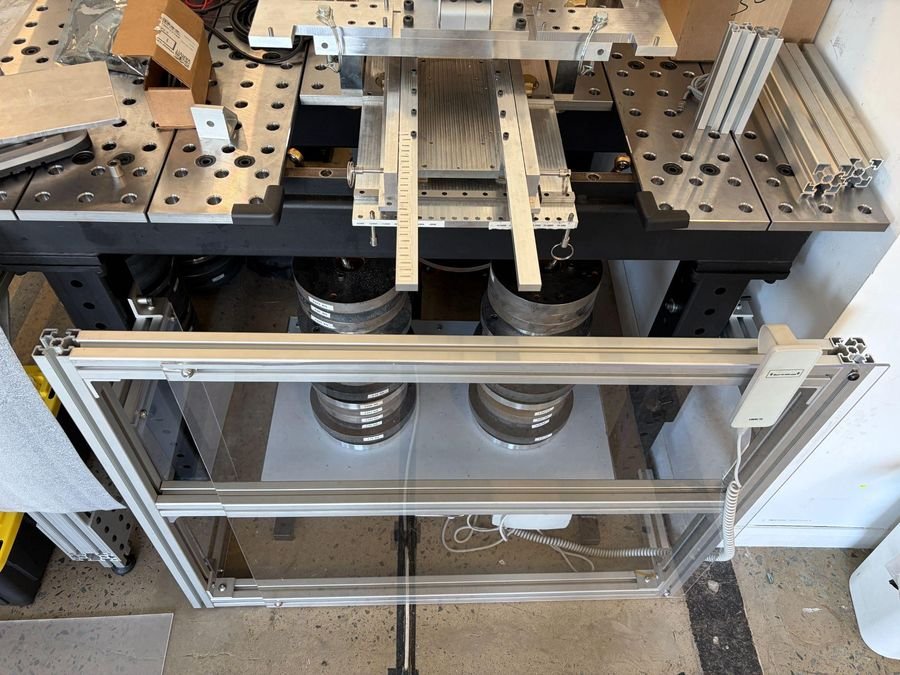
Forcen
Mechanical Engineering / Testing Intern, Toronto, ON
UW Rocketry
Mechanical Design Lead, Controls Subteam
-
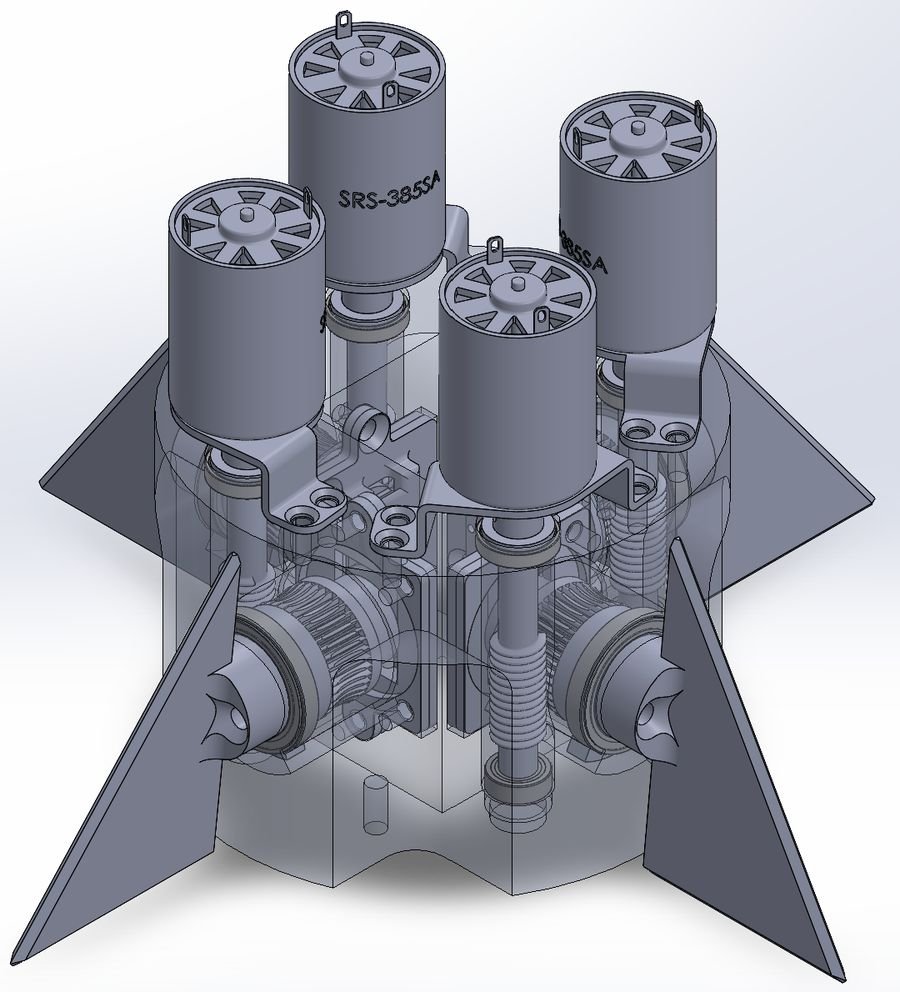
4 Actuator Canards System Prototype
The team's first four-actuator canard system, and its first worm gear drive.
-
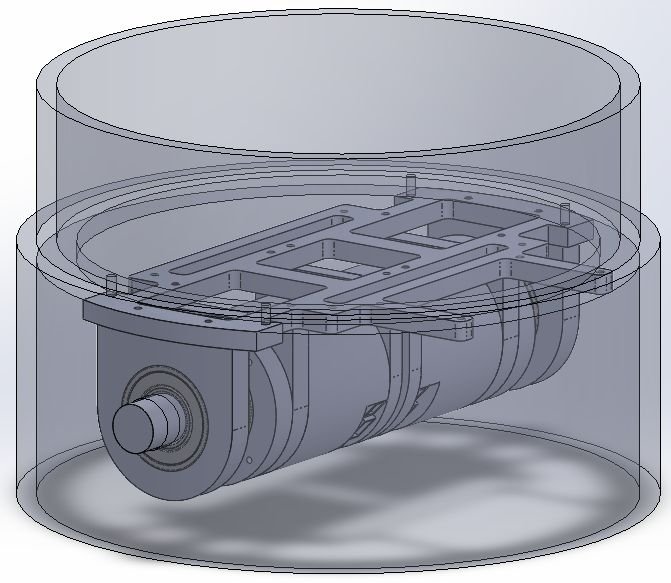
Unlinked Canards Control System
Sole designer on the first independently actuated canard system, ~600 g lighter than the linked design.
-
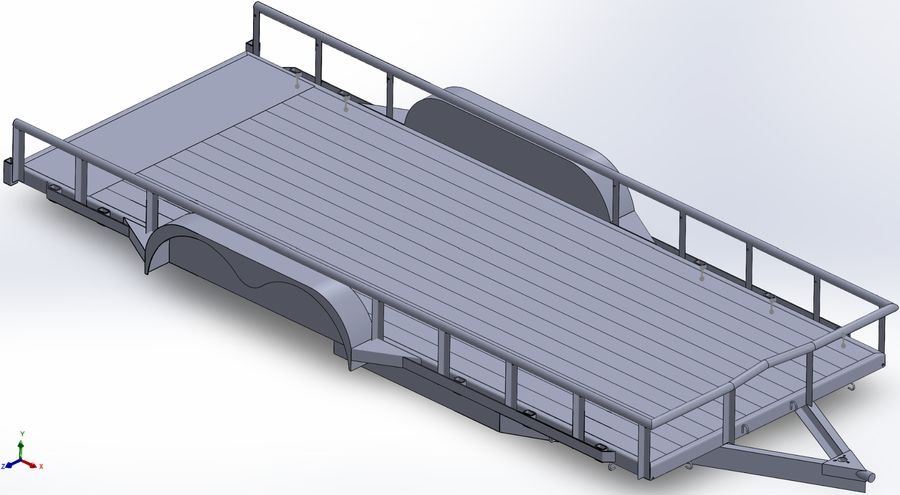
Transport Trailer Full-Scale CAD
Full-scale CAD of the 8 × 18 ft transport trailer, dimensioned from the real thing.
Other projects
Personal, team and competition work
-
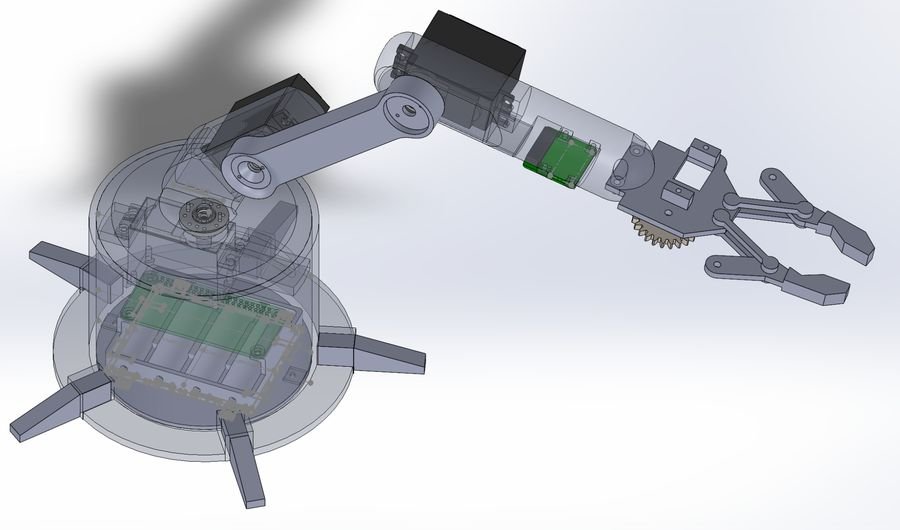
3 Degrees of Freedom Robotic Arm
A 3D-printed arm that finds an object with a camera, picks it up, and throws it.
-
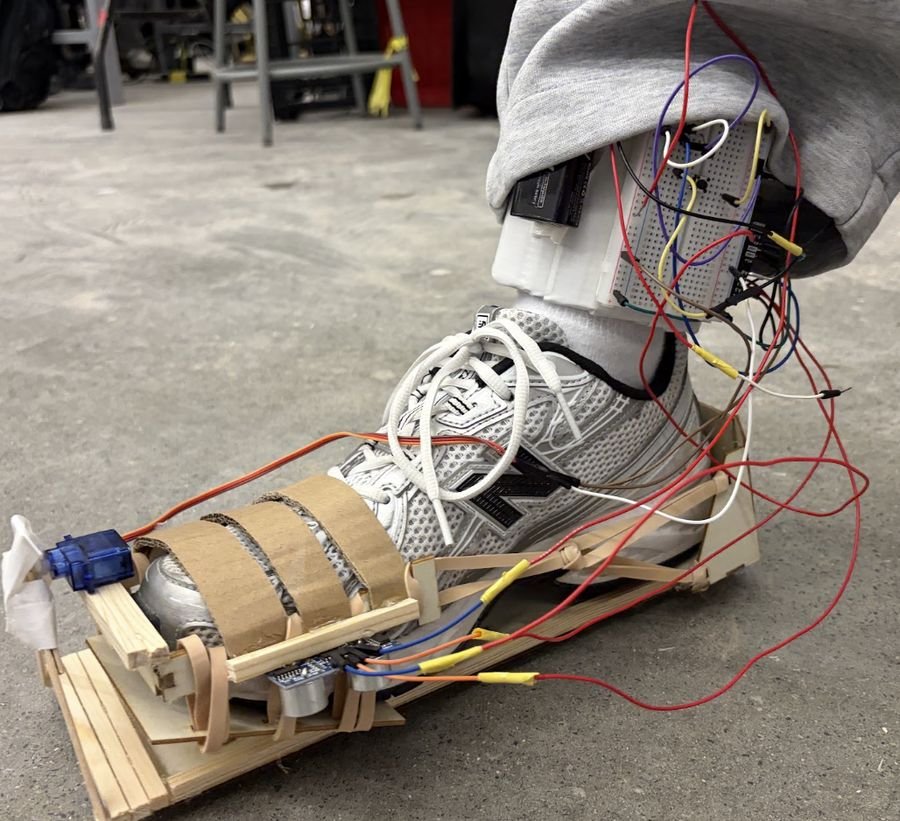
Autocleat, self-deploying ice cleats
Shoe attachment that drops ice spikes only when the foot is off the ground. 3rd place at EngHacks.
-
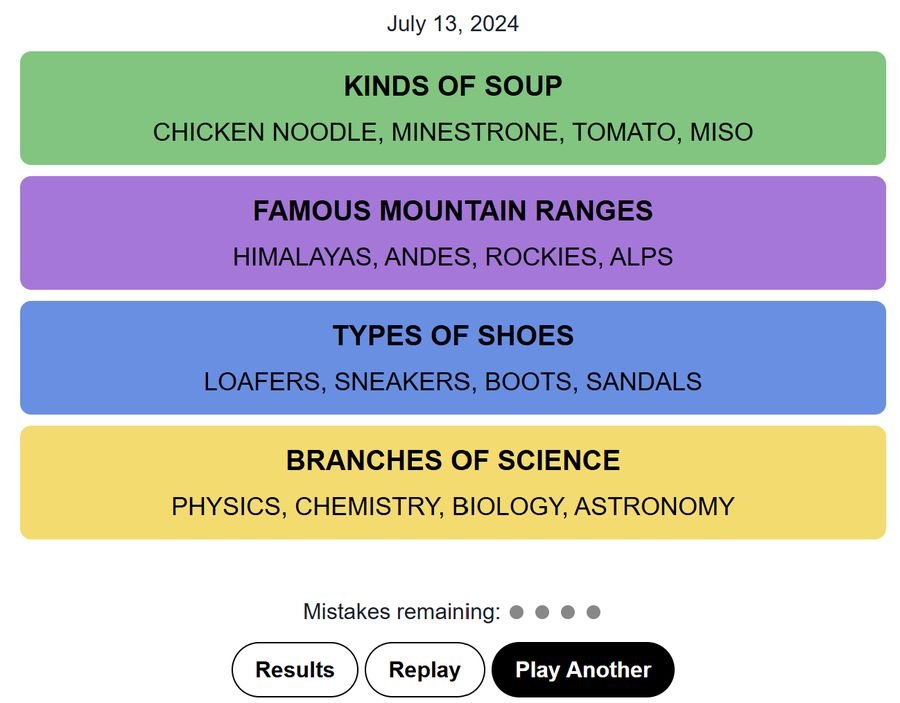
NYT Connections web and CLI solver
Python solver hitting 65-75% top-3 accuracy on real puzzles, with a web and CLI front end.
-
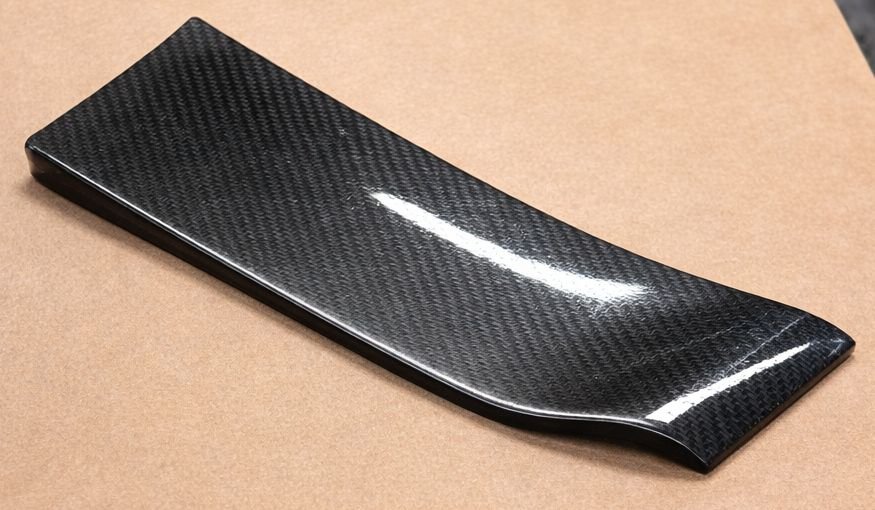
Y-250 Front Wing Manufacturing
Carbon fibre layup of the team's first inward-swept, cambered front wing flaps.
-
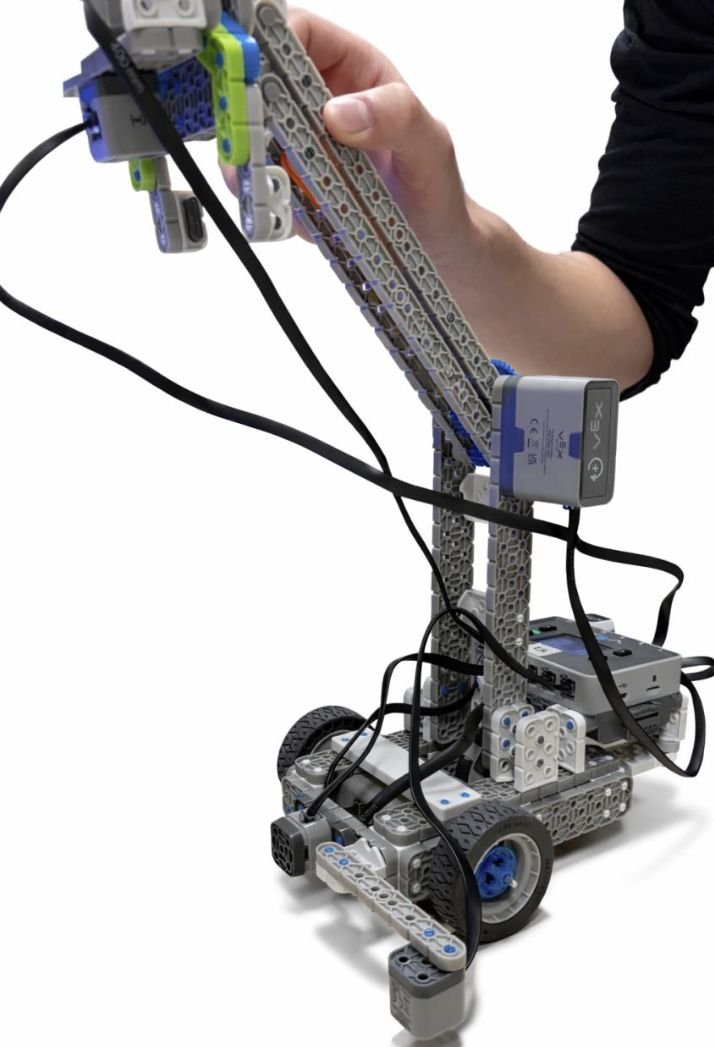
VEX Autonomous Maze Navigator
Autonomous VEX IQ robot that maps a maze, retrieves an object and returns by the shortest path.